Offroad Traversability Mapping
ELPIS Lab, Thesis
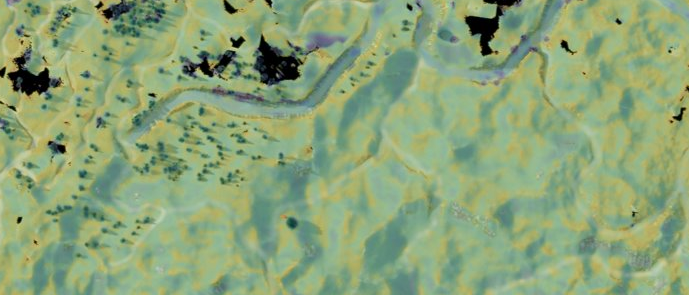
- Designed an online offroad traversability mapping algorithm utilizing self-supervised learning
- Integrated mapper into a full offroad exploration stack in simulation
- Performed literature review on traversability analysis
- Read the DGT-Map preprint
Tools: Python, Carla, ML